Platforms Robotics
Kova K2
Flagship humanoid · rev D
Platform design
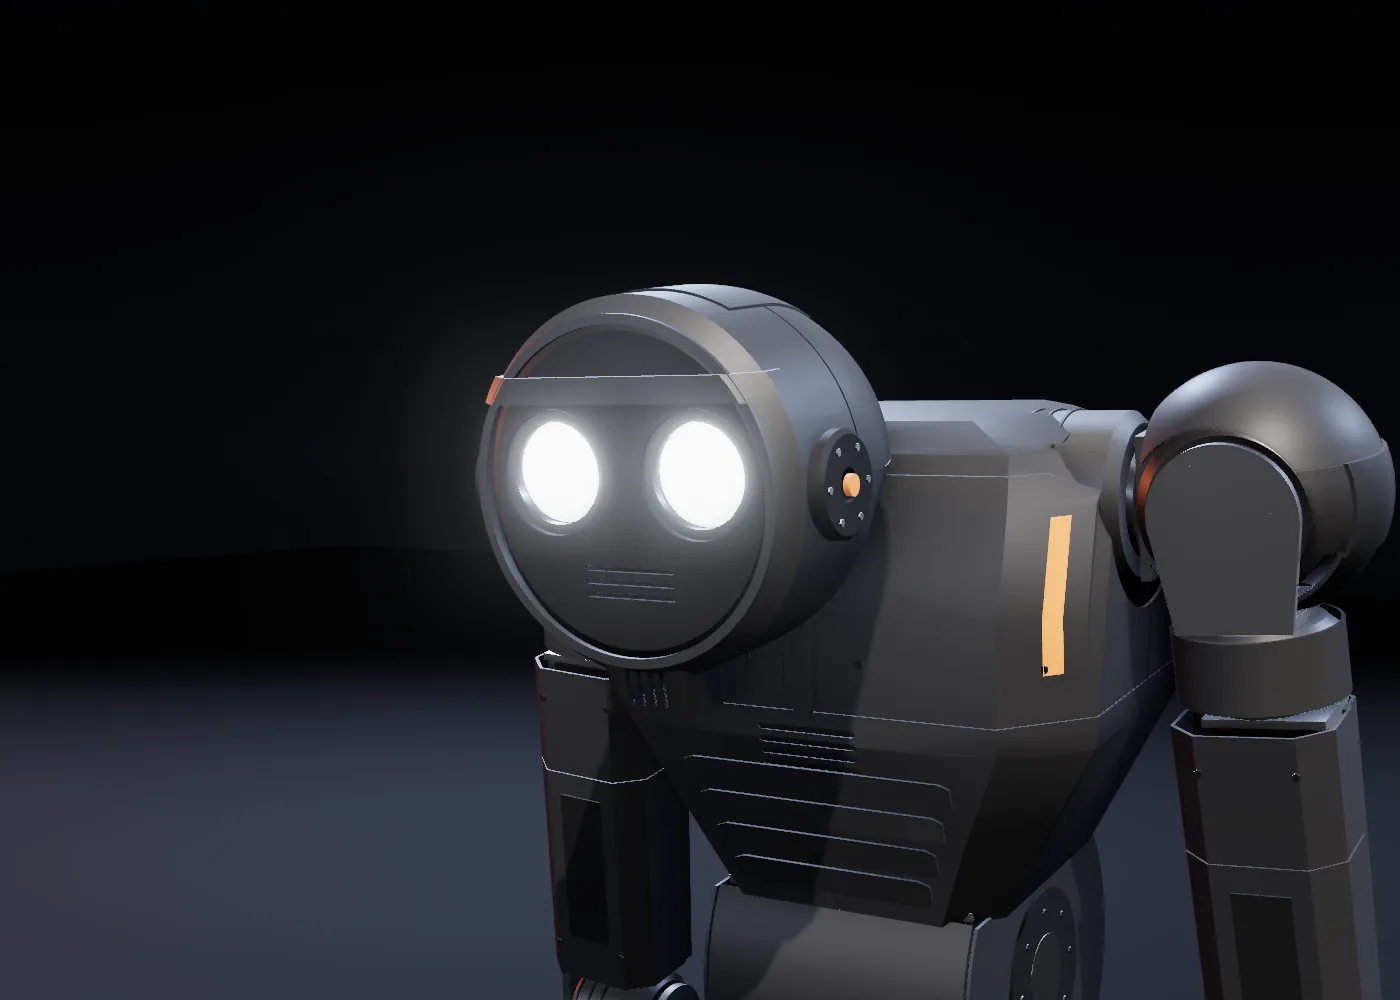
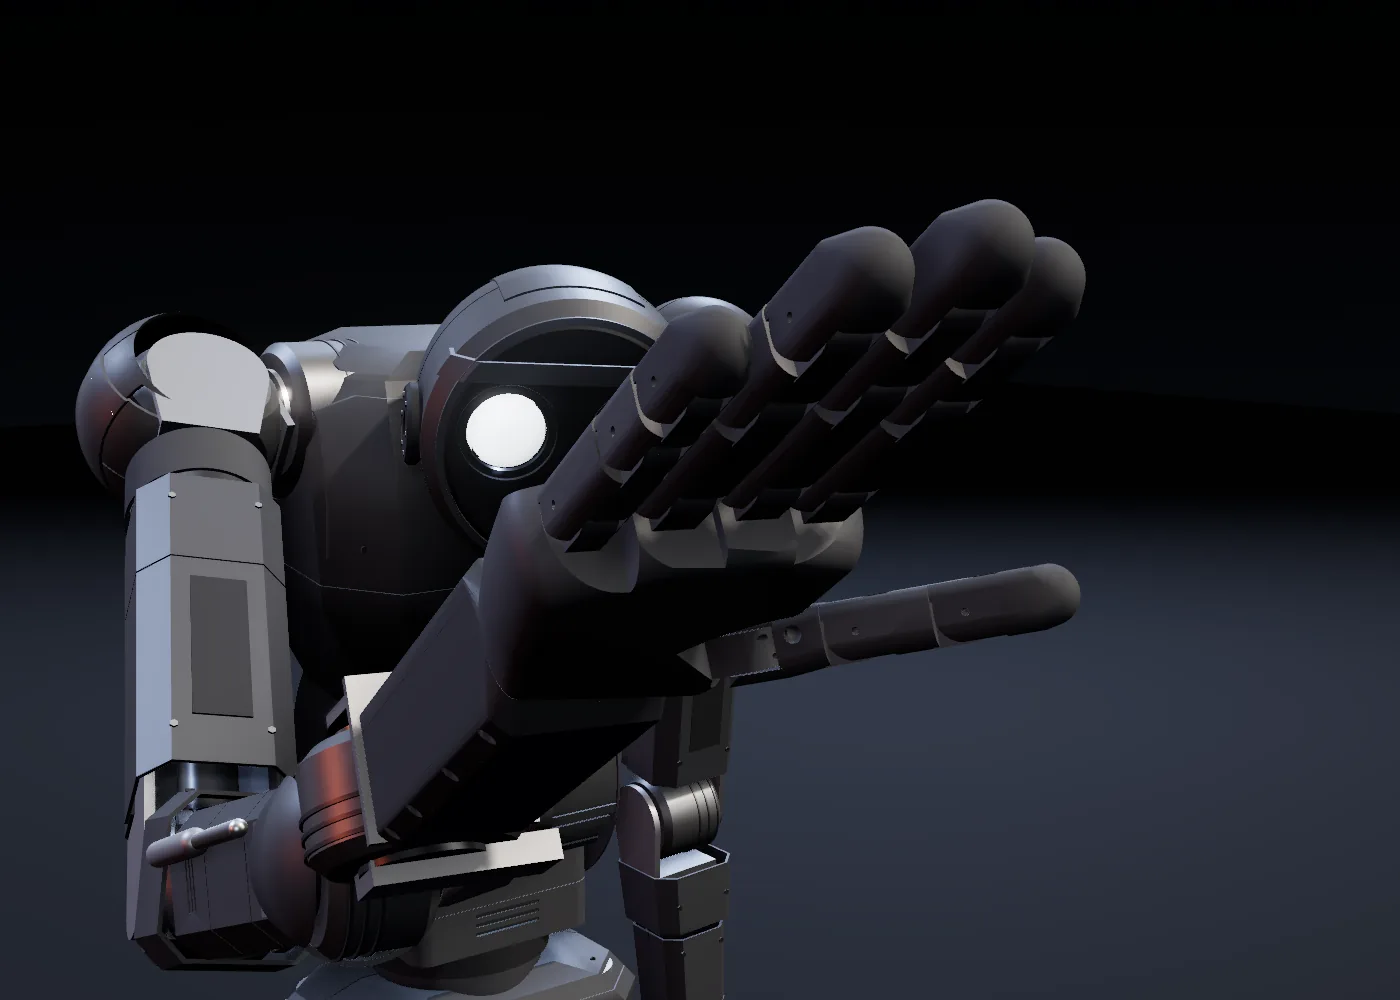
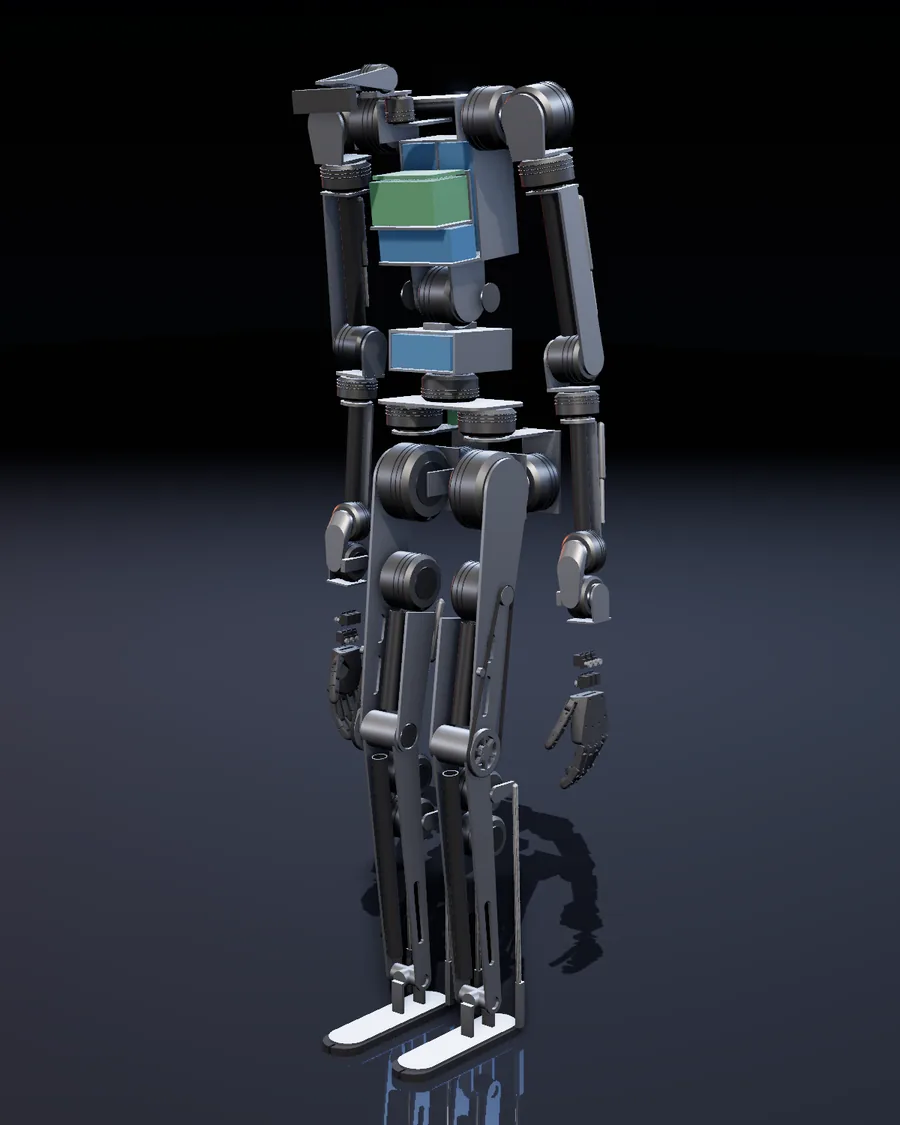
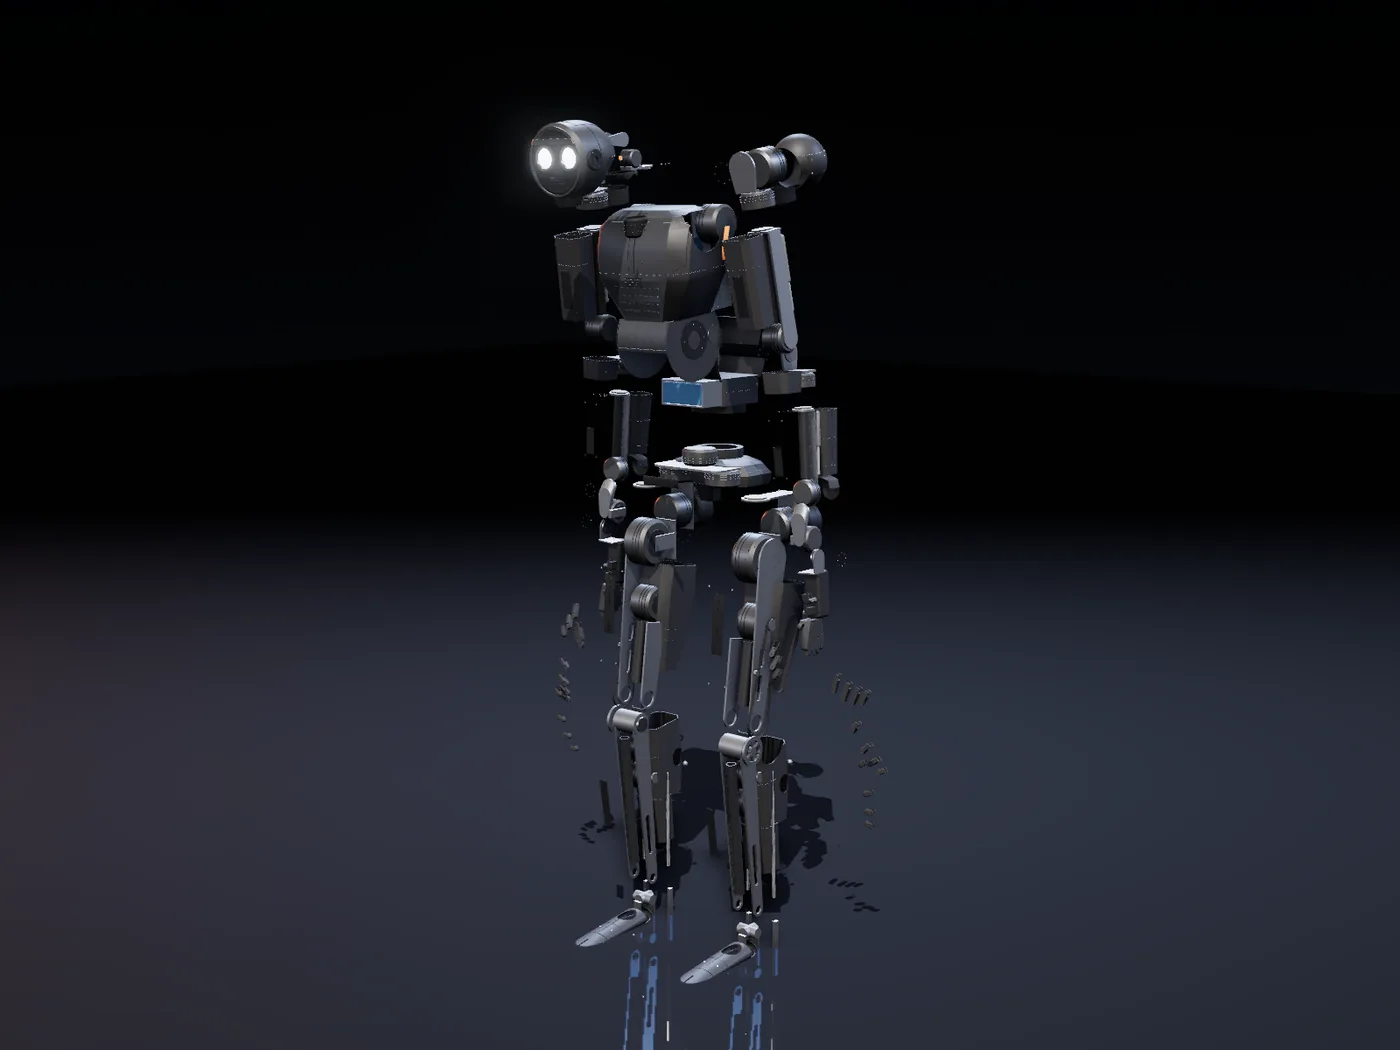
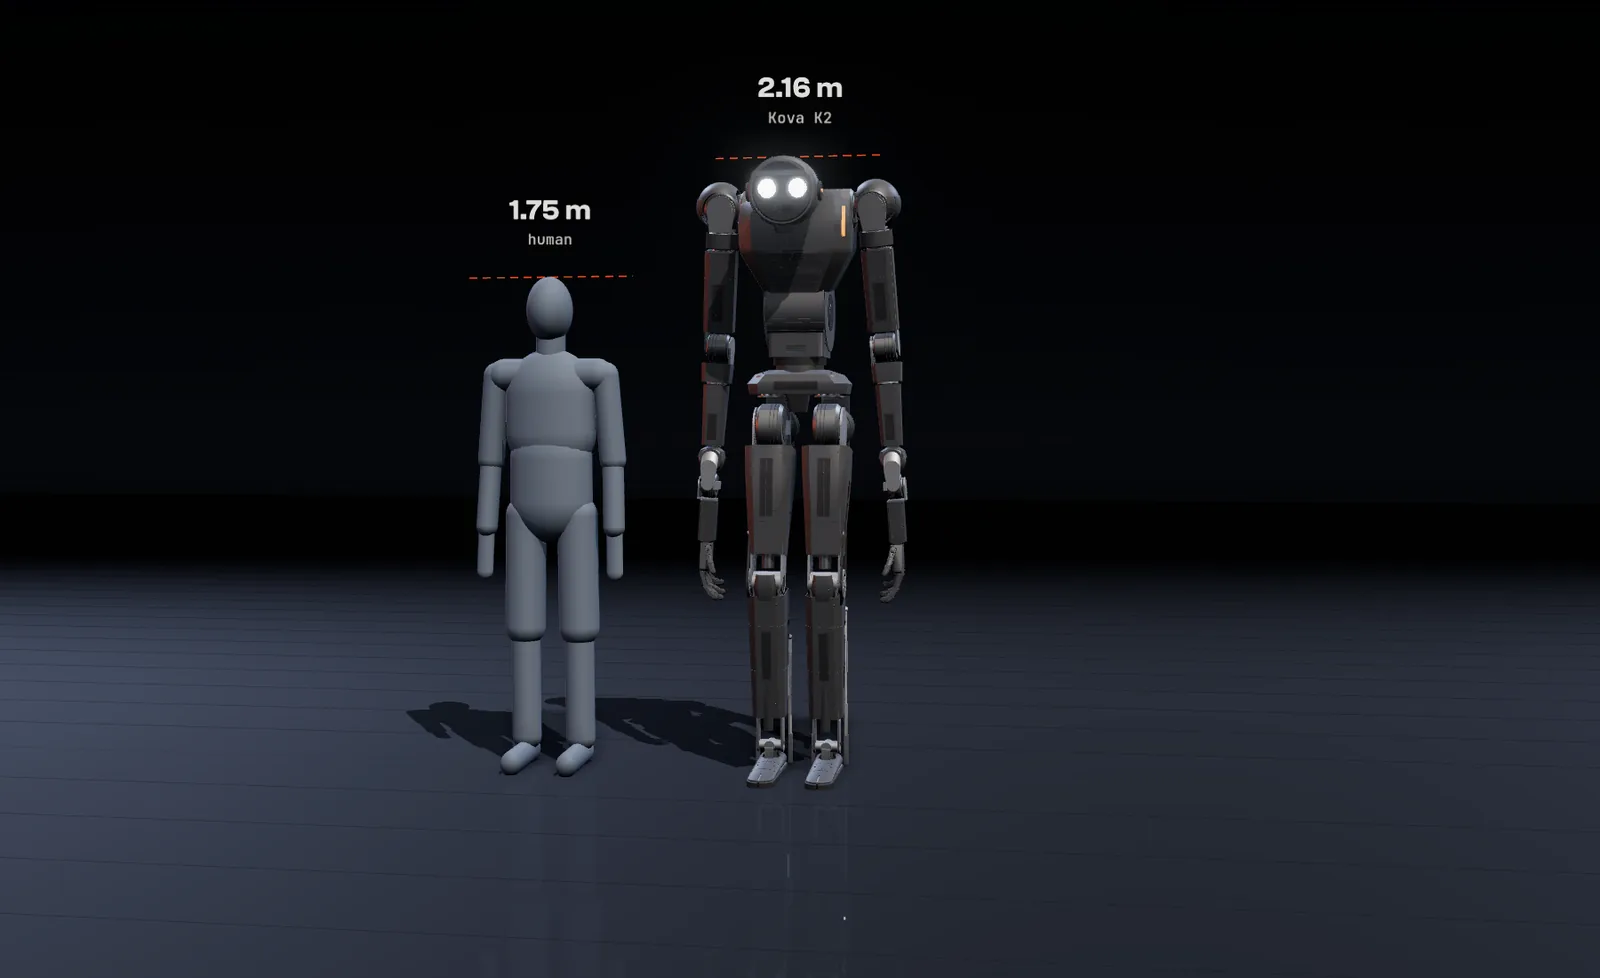
A 2.16 m industrial-style humanoid: long limbs, an armoured chest and abdomen, a 2.9 kWh hot-swap battery, and AGI Hand v2s scaled 1.23×. Every joint can be explored in the browser simulator.
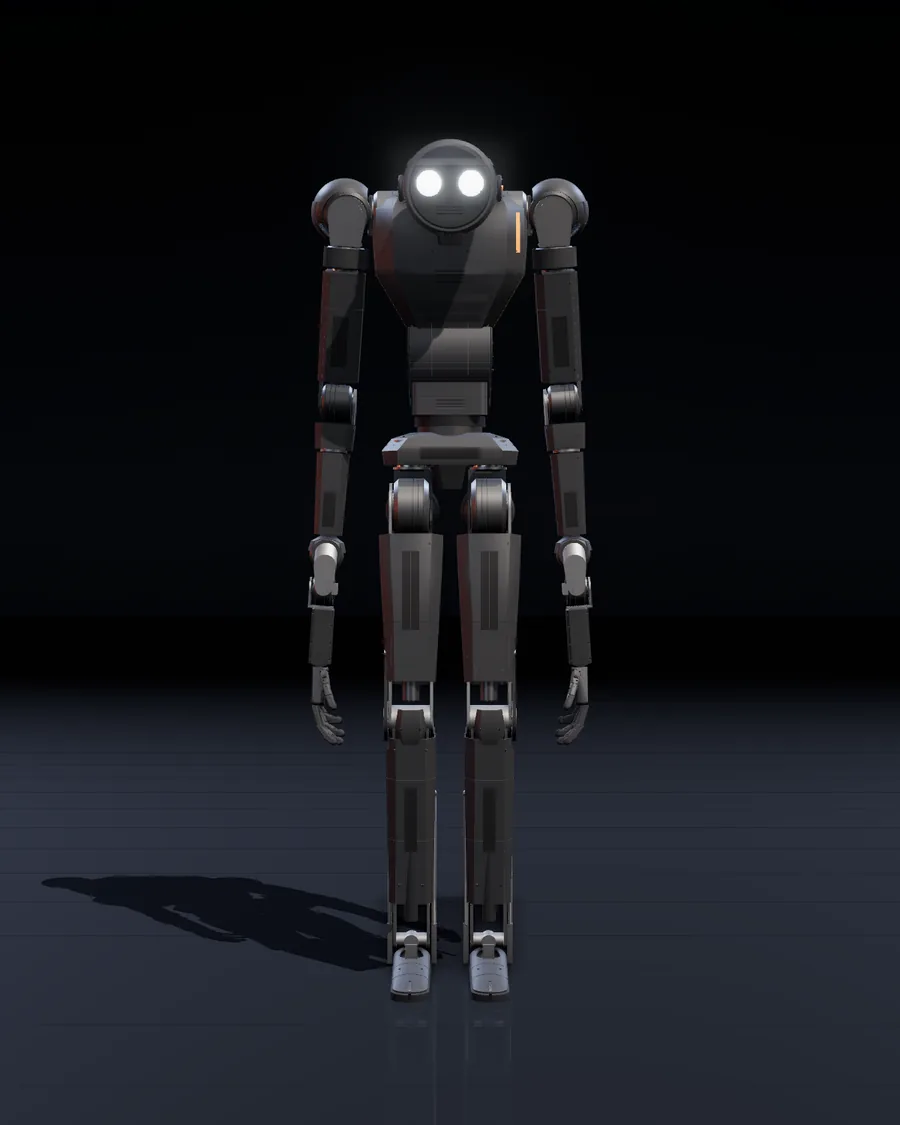
Headline numbers
What the CAD says.
Each value is tagged Computed, Datasheet or Estimate.
- Standing height
- 2,156 mm Computed
- Total mass
- 96.3 kg Computed
- Body degrees of freedom
- 30 Computed
- Battery
- ≈2,948 Wh Computed
- Runtime
- ≈6.3 h / ≈2.8 h Estimate
- Compute
- Jetson Thor class Datasheet
- Actuators
- 30 modules Computed
- Safety
- Hardwired e-stop
- Perception
- OAK-D Pro W Datasheet
- Neck range
- ±45° yaw Computed
- Breadth × depth
- 713 × 550 mm Computed
- Hands
- AGI Hand v2 · 1.23× Computed
Plus two AGI Hand v2s with 6 servo motions each. 61 joints in the URDF/MJCF.
Three hot-swap 13S4P cartridges plus a fixed bridge pack: 182 Molicel P45B cells, 46.8 V nominal. The pack design is an estimate.
Standing (~400 W) / walking (~900 W), using 85 % of the pack. The power draws are assumptions.
NVIDIA Jetson T5000 module on a shelf in the upper chest.
MyActuator RMD-X15, X12 and X8 on the high-load joints. RobStride RS04, RS03, RS06 and RS00 elsewhere.
Upper-back button on a safe-torque-off loop. EtherCAT and CAN-FD buses.
Luxonis stereo/RGB camera behind the two round eyes.
Pitch −30° to +25°, from a head-clearance sweep in the CAD.
Across the shoulder caps.
Scaled shells. The servos and spools stay real size.
K2 is a concept design, and its simulator is kinematic. Figures are computed from the CAD model, taken from component datasheets, or estimated, as tagged.
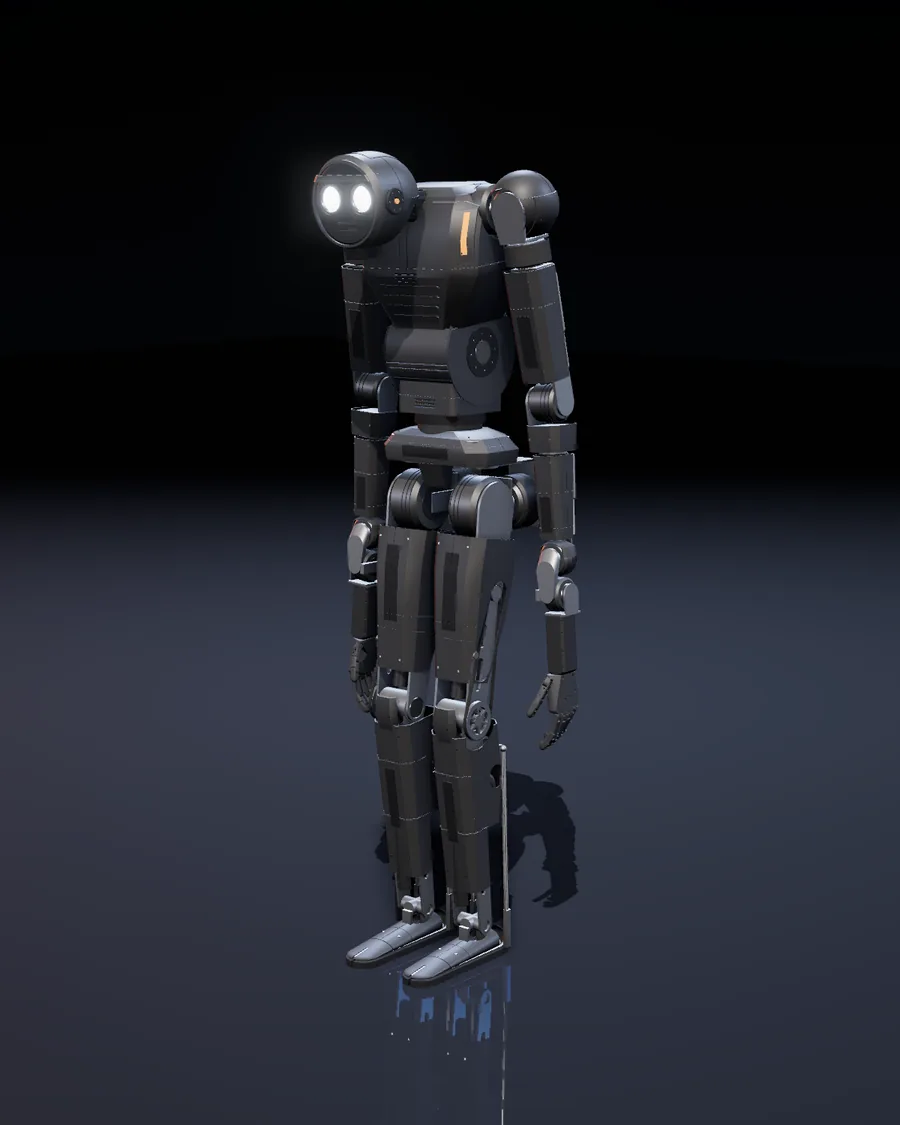
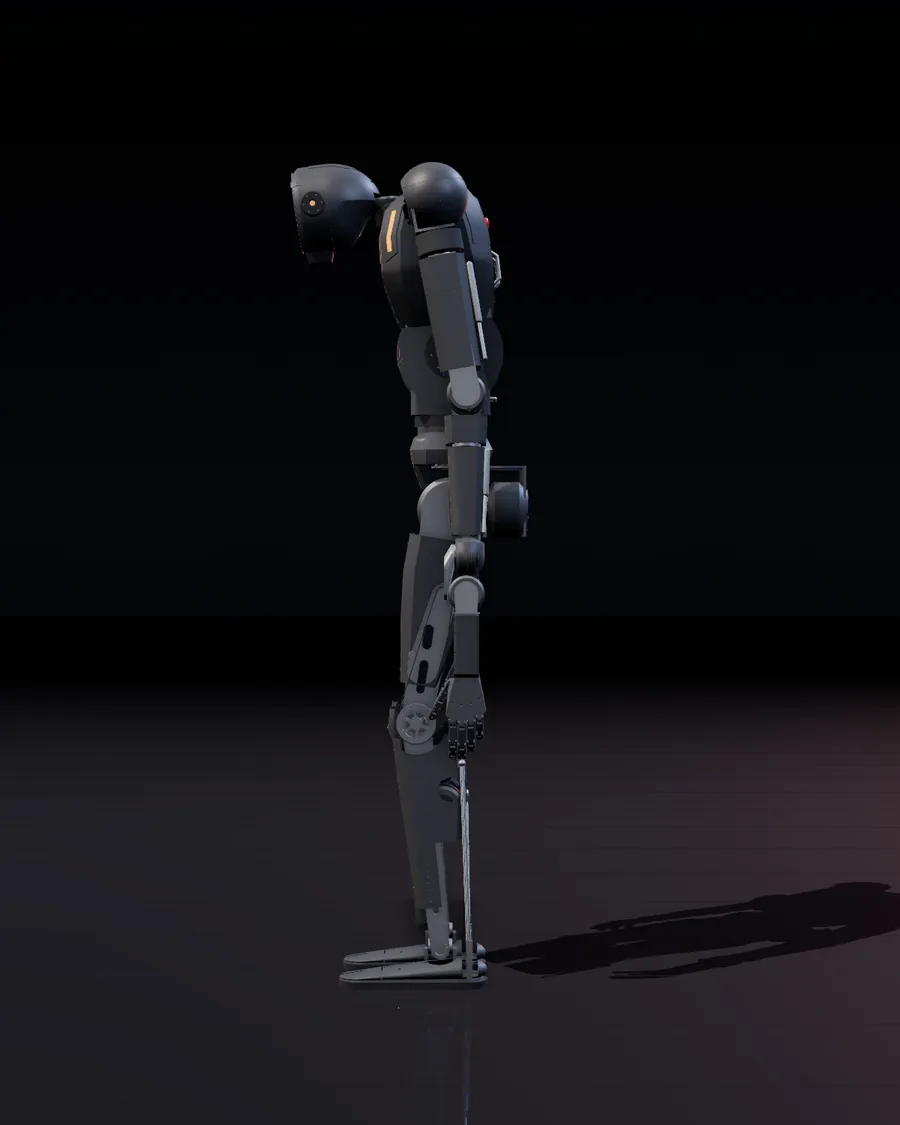
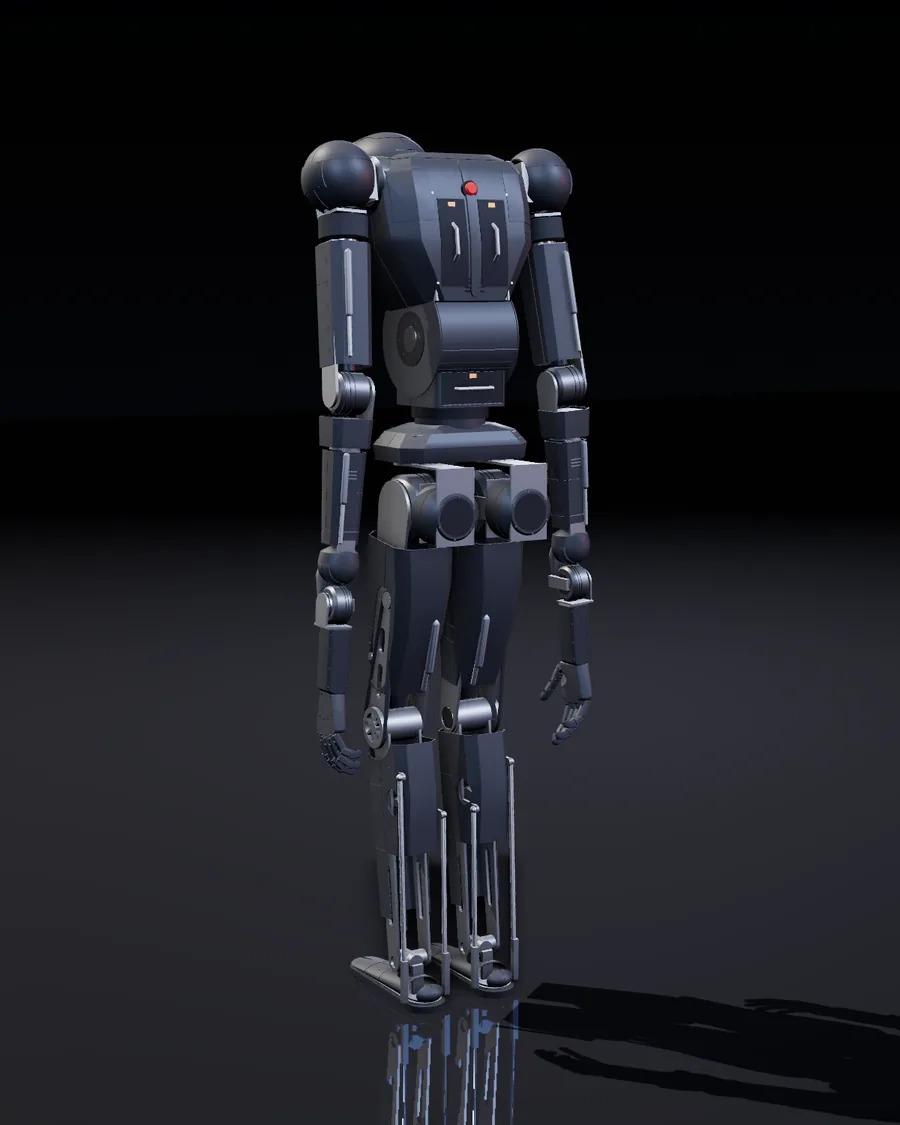
Renders
From every side.
Actuators
Thirty drives, sized for 96 kg.
Peak and rated torque are from the vendor pages Datasheet. The knee uses a 2.4:1 belt, giving 768 N·m peak at the joint.
| Model | Qty | Peak / rated (N·m) | Used for |
|---|---|---|---|
| MyActuator RMD-X15-450 | 2 | 450 / 145 | Hip pitch |
| MyActuator RMD-X12-320 | 9 | 320 / 85 | Hip roll, knee, shoulder pitch and roll, waist pitch |
| MyActuator RMD-X8-120 | 6 | 120 / 43 | Ankles (two per ankle, parallel), elbows |
| RobStride 04 | 3 | 120 / 40 | Hip yaw, waist yaw |
| RobStride 03 | 2 | 60 / 20 | Shoulder yaw |
| RobStride 06 | 6 | 36 / 11 | Wrist roll, pitch and yaw |
| RobStride 00 | 2 | 14 / 5 | Neck pitch and yaw |
| Feetech SCS0009 | 12 | — | Hands (6 per AGI Hand v2) |